



The remaining articles in this Loop Signature series will examine the dynamics of nearly every type of process encountered in industrial control analysis. The goal is to help readers recognise a process’s dynamics and apply the most suitable tuning method. Many participants in the Part 2 courses have since contacted me to explain how they successfully tuned difficult plant processes that had previously remained in manual mode or performed poorly in automatic.
Understanding this part of the series requires a basic knowledge of frequency plots. Most people who have studied control theory will have encountered them at some point, but experience shows that few fully understood the concept, and even fewer have applied it in practice. This is likely because frequency plots cannot be generated without suitable loop-analysis tools, such as Protuner Loop Analysis software.
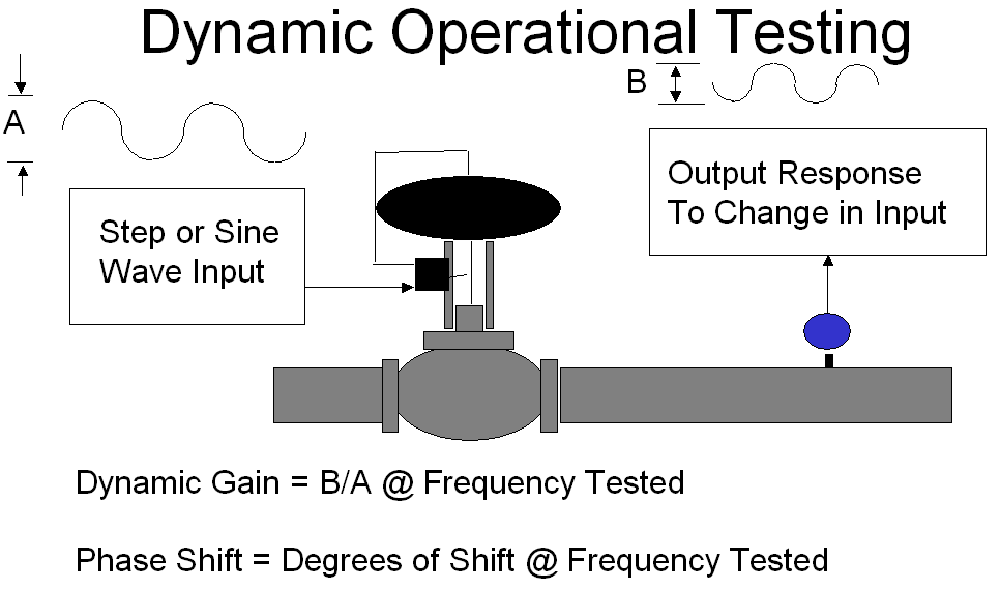
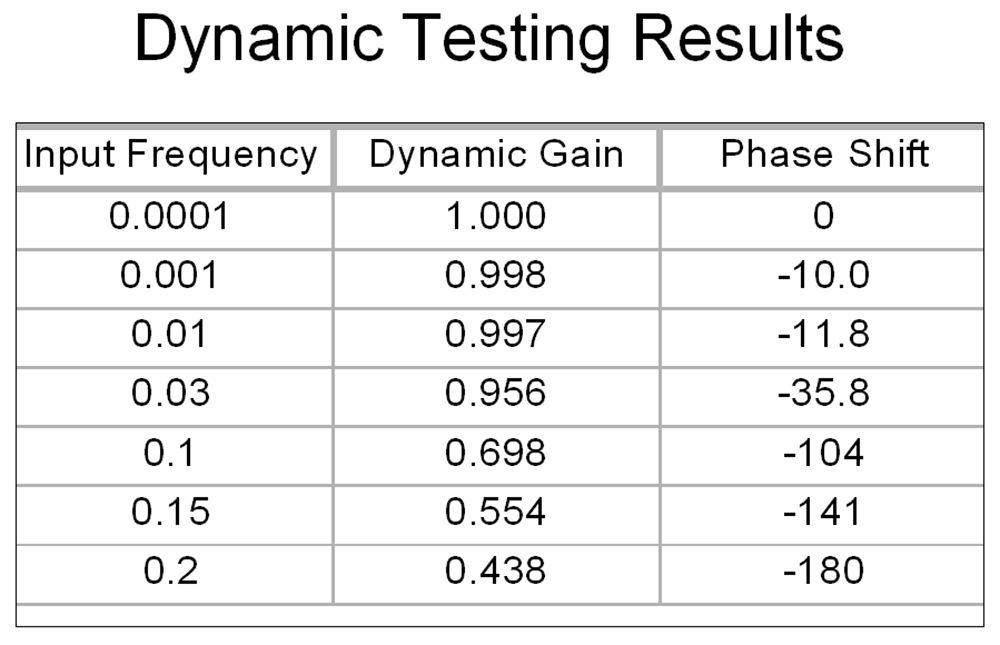
The basics of tuning theory were covered in Loop Signature no. 23. Following the original ideas postulated by the early mathematicians who developed the theory, for example Nichols, one should perform a full frequency response test on a control loop. As illustrated in Figure 1, a sine wave is generated onto the input to the process/ process demand. Initially, the sine wave must be at a very low frequency. A sine wave of the same frequency will appear at the output of the loop/ process variable. The amplitudes of the input and output sine waves are measured and their ratio calculated. This is called the dynamic gain. The phase difference is also measured. The test would then be repeated at a slightly higher frequency. This procedure is then repeated with higher and higher frequencies until the output lags the input by a phase difference of -180°. At this point, if the control loop were closed, the contribution fed back to the process from the feedback would start pushing the valve in the wrong direction and instability would result. The table shown in Figure 2 is an example of such a test.
The next step in the tuning procedure is to draw a frequency plot from the test data, and various mathematicians all came up with slightly different plots. A Bode open loop plot is shown in Figure 3, which consists of two graphs: firstly dynamic gain versus frequency, and secondly phase lag versus frequency.
To obtain optimum tuning one manipulates the shape of the plots. This will be discussed later.
Unfortunately, this methodology for tuning cannot be used in real life as it would take far too long, especially on processes with very slow dynamics such as temperature loops, and also because placing many critical loops in oscillation in a real plant environment is not permitted. This theory is not some mathematical ‘claptrap’, in fact, it is extremely accurate. If the tests could be done as discussed and if no loop problems existed, it would be possible to come up with really good tuning. Tools that can generate accurate frequency plots are therefore extremely valuable.
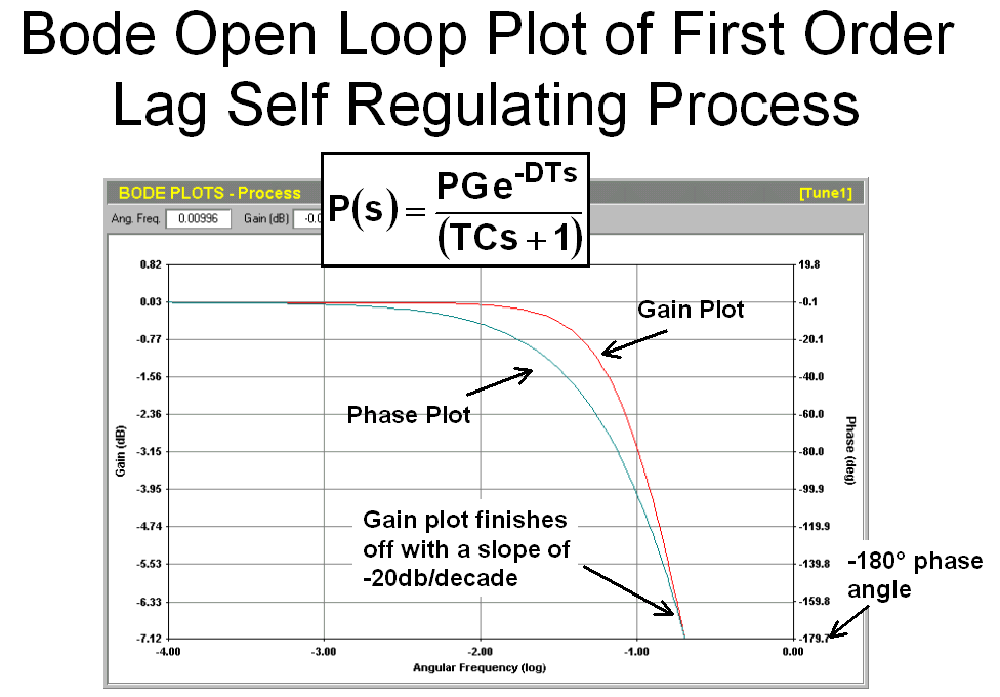
The first process type examined is the simple first-order lag, deadtime, self-regulating process discussed earlier in this series. Many simpler industrial plant processes follow this model.
The Bode open loop plot of this process, shown in Figure 3, is now examined in more detail. The Bode consists of two graphs. Firstly, dynamic gain versus angular frequency (in radians/second), and secondly, phase lag versus angular frequency. Dynamic gain is in decibels where:

Here, absolute gain refers to the ratio of the two gains measured in percent of measurement range. The phase lag is in degrees, and the horizontal frequency axis is a logarithmic scale.
For this particular dynamic, working from lower frequencies on the left to higher frequencies on the right, the gain plot starts off horizontally and then starts dropping and finishes with a slope of – 20 dB/decade at the point where the phase plot reaches –180°. The slope would be – 40 dB/decade if there had been two lags, and – 60 dB/decade for three lags. Like all self-regulating processes, the phase plot also starts horizontally at 0° and ends at - 180°.
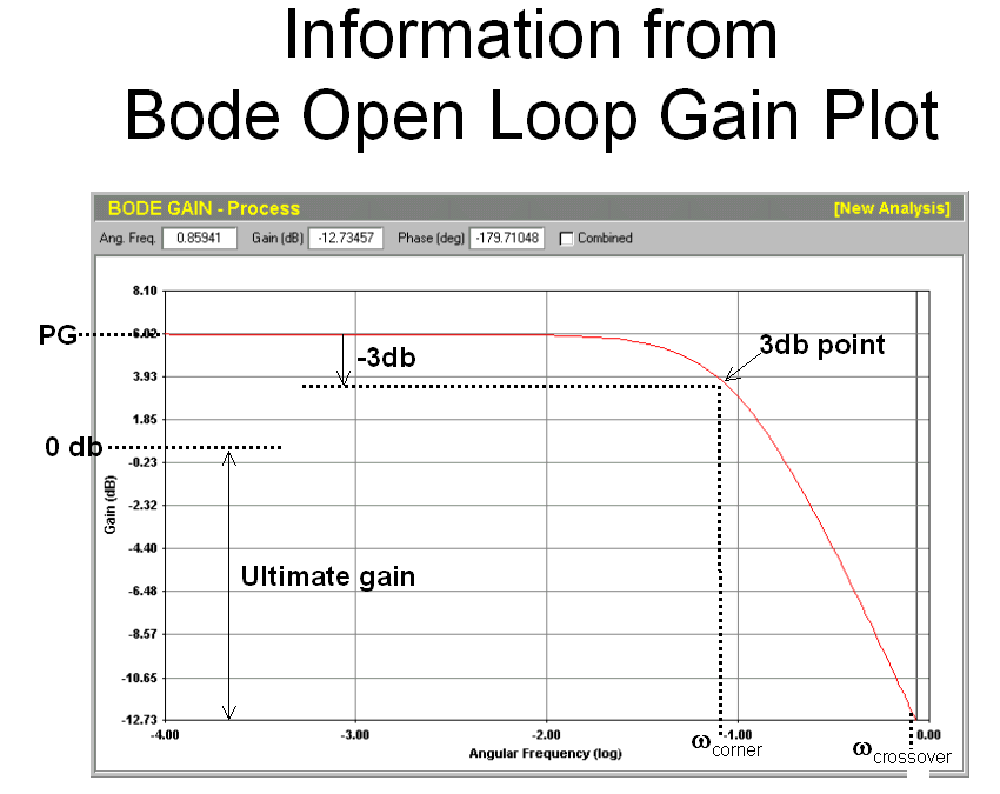
Useful information can be derived from the open-loop gain plot. The gain value where the plot intersects the vertical dynamic gain axis is the process gain, obtained by applying a step change to the controller output, as discussed in Part 1 of the Loop Signature series. This is logical because if the frequency is slow enough, the dynamic gain must equal the process gain.
The frequency where the phase lag reaches - 180° is known as the crossover frequency, or the ultimate frequency.
Further information can be obtained by moving down by - 3 dB from the intersection of the gain plot with the gain axis, then drawing a horizontal line rightwards to intersect the gain plot at a frequency called the corner frequency. The lag time constant can then be derived using the following formula:

The last piece of information easily obtained from this plot is the ultimate gain, which will be discussed later.
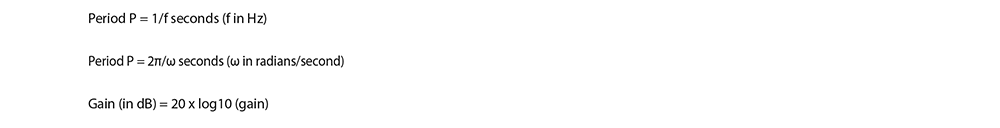
In the meantime, here are a couple of useful formulae when working with frequency plots:
To be continued in the next Loop Signature article.
Michael Brown is a retired expert in control loop optimisation, possessing over five decades of experience in process control instrumentation. His primary focus has been consulting and delivering instruction on practical control loop analysis and optimisation. He has conducted training and optimised control systems at numerous facilities internationally. Mr. Brown continues to author articles reflecting his extensive work, and his courses remain accessible for purchase in PDF format. Additionally, he manages the distribution of Protuner Loop Optimisation software and welcomes inquiries regarding loop-related issues.
Contact details: Michael Brown Control Engineering CC,






© Technews Publishing (Pty) Ltd | All Rights Reserved
 printer friendly version