



The practice of industrial feedback control is one of the most misunderstood engineering disciplines in the world. The theory was developed by eminent mathematicians in the early 1900s and was based on highly mathematical principles which are, in practice, extremely hard to apply in an industrial process plant without the right tools. Teaching is invariably almost entirely on the mathematics with no practical explanations. Most practitioners entering the field find they cannot use the theory, and develop their own ‘feelings’ on how to do things. Many of their beliefs are actually incorrect. As a result about 85% of all control loops worldwide are operating completely inefficiently in automatic. (This last statement is often hotly disputed by ‘experts’ in the field, but after optimising many thousands of loops, we stand fully behind it.)
Common misconceptions and deadtime dominant processes
Fallacies resound around the industry such as:
• Any control problem can be solved by tuning.
• Smart (computerised) measuring instruments and positioners must be right.
• You do not need highly skilled people to make control systems work and particularly to tune controllers.
However, the subject that seems to have the most misconceptions, and of which a lot of rubbish is published on Internet control discussion groups, is how to control deadtime dominant processes.
A deadtime dominant process is defined as one where the deadtime is greater than or equal to the dominant lag. One of the best examples of such a process is weigh feeder control on conveyor systems as typically used in mining applications. This is due to the fact that the measuring point is often very far away from the feeders.
Deadtime is the ‘bad guy’ in feedback control as it introduces phase lag into the loop and can result in instability if badly tuned. (An interesting fact is that theoretically a process with zero deadtime cannot make a loop unstable, irrespective of the tuning. Why I say ‘theoretically’ is because in the real world there will always be some deadtime somewhere in the components of the control loop.)
Tuning of deadtime processes has always been a bit of a puzzle. In the original Ziegler-Nichols paper on tuning published in the early 1940s they specifically mentioned that they couldn’t give tuning formulae for deadtime dominant processes.
In real life, most of these processes are incredibly badly tuned. However, if you think of it, we all know what to do when controlling long deadtime processes. I am sure that we have all experienced taking a shower where it takes a long time for the temperature to change after you adjust one of the taps. If you turn the tap too much then a deadtime later you suddenly freeze or else scald yourself. You quickly learn to turn the taps a little at a time and then wait until the resultant change is felt. So what you have learnt is to slow the control down! The secret of controlling these processes is to slow the control down.
The golden rule is: “The longer the deadtime, the slower the tune.”
In the case of a self-regulating process like a weigh feeder, once the integral term is set correctly (discussed in previous Case Histories), then all you have to do is to reduce the proportional gain until the process response to setpoint changes is stable.
Generally, one can tune a deadtime dominant process to get to a new setpoint within two deadtimes. The problems arise when the process experiences load disturbances that are too frequent for the control to catch. Unfortunately, there is nothing that can be done about this as far as tuning is concerned. You have to explore other strategies like physically trying to reduce the deadtime, or employ feedforward control if possible. Feedback control does have its limitations. There are of course special model predictive controllers on the market that theoretically can give improved control on these processes, but I have personally never seen one used successfully on industrial processes.
D is for Do Not Use
Some of the things I have seen written in articles and on Internet chat groups, many by really experienced control engineers, are quite unbelievable. For instance, a professor of control emphatically stated that deadtime dominant processes cannot be controlled at all by feedback controllers. But the most common fallacy of all on this subject is that the derivative term must be used to try and speed up the response. This is rubbish. One can easily prove that using the derivative messes up the tuning and actually makes it much worse. One of my early mentors said that when it comes to deadtime dominant processes, the D does not stand for Derivative, but in fact means, ‘Do Not Use!’
Remember that derivative was introduced into the controller to try and speed up control of extremely slow processes. This is the exact opposite of what you want to do when controlling deadtime dominant processes. You need to slow the control down.
A practical example
In general, very few people know how to tune these processes. Most of them are tuned terribly badly with the vast majority responding to changes unbelievably slowly.
A good example of this was seen when I recently performed optimisation at a mine in Portugal. The control was for a weigh feeder where testing response to input changes on the processes showed a 45 second deadtime. (The lag time constant in the response was effectively zero, making this what is called a true ‘deadtime only’ process, which is practically quite a difficult process to tune if you have not been trained on the methodology, and if you do not have a proper tuning package that works on such processes.)
Figure 1 is an ‘as-found’ closed loop test, with the original tuning where a 2,5% step change in setpoint was made.
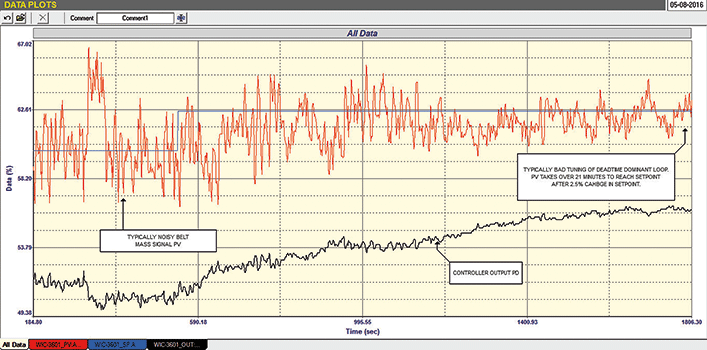
It took an unbelievable 22 minutes for the process to get to the new setpoint. The as-found tuning was:
P = 0,16, I = 480 seconds/repeat.
Figure 2 is the final closed loop test with the new tuning. This time a 5% step change in setpoint was made, and it then took just 90 seconds for the process to get to the new setpoint. This is about 15 times faster! Also, it is worth while noting what I said earlier: “You can normally tune deadtime dominant processes so they can get to new setpoints within two deadtimes.”
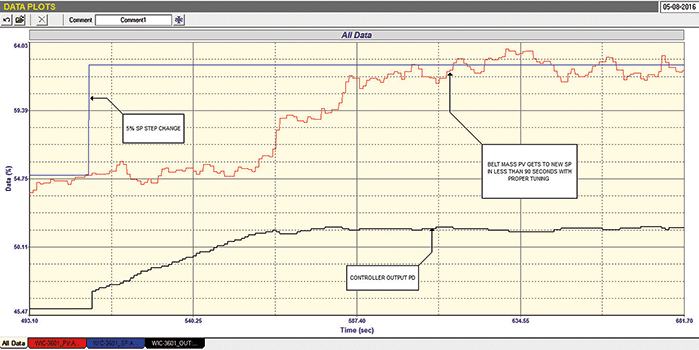
The new tuning is: P = 0.17, I = 14.6 seconds/repeat. This is a very dramatic difference and is a lovely illustration of typically bad tuning of these difficult to control processes.
Michael Brown is a specialist in control loop optimisation with many years of experience in process control instrumentation. His main activities are consulting, and teaching practical control loop analysis and optimisation. He gives training courses which can be held in clients’ plants, where students can have the added benefit of practising on live loops. His work takes him to plants all over South Africa and also to other countries. He can be contacted at Michael Brown Control Engineering, +27 (0)82 440 7790, [email protected], www.controlloop.co.za






© Technews Publishing (Pty) Ltd | All Rights Reserved
 printer friendly version