


Motion Control & Drives


Thousands of robots swarm together collaboratively

January 2015 Motion Control & Drives

Each low-cost, three-legged robot moves around with the help of two motors that vibrate at different frequencies, causing it to move across a surface on its rigid legs. It communicates with its neighbours, measuring their proximity through infrared transmitters and receivers. After being programmed to form a set shape such as the letter K or a starfish, each one in turn navigates its way to a final position using primitive behaviours – following the edge of a group, tracking a distance from the origin or maintaining a sense of relative location. If a traffic jam forms, nearby robots sense it and co-operate to fix the problem.
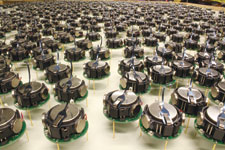
Credit: Harvard SEAS.

“Each robot is identical and is controlled by exactly the same program,” explains Dr Michael Rubenstein from Harvard University School of Engineering & Applied Sciences. “The only thing they have to go on to make decisions is what their neighbours are doing.” The robots are much simpler than many conventional robots, for example individuals may have trouble moving in a straight line; but at full scale the smart algorithm controlling them overcomes individual limitations and the robots can complete a human-specified task – like assembling into a particular shape.

Infrared control

Although the Kilobots can communicate with their neighbours, they have no sense of a broader environment. Four robots mark out the origin of a coordinate system while the remaining robots receive a 2D image of the shape. The initial set of instructions is beamed to the robots via infrared, after which they work autonomously, requiring no further human intervention. Starting with a random selection, if they are in a position to move they motor slowly around, flashing their infrared lights to broadcast information to other Kilobots nearby. They then assemble into the specified shape.

Inspiration from nature

The self-organising behaviour was inspired by the cooperative activities of insects like army ants. The Harvard team aims to provide a physical model for advancing the understanding of collective behaviour, creating artificial swarms with the capabilities of natural ones. The Kilobot demonstrates how simple machines performing simple behaviours can create complexity in a group and that robots can be programmed to perform useful functions by coordinating interactions among many individuals. “The beauty of biological systems is that they are elegantly simple yet in large numbers accomplish the seemingly impossible. At some level you no longer even see the individuals, you just see the collective as an entity in itself,” says research leader Radhika Nagpal, professor of computer science at the Harvard School of Engineering and Applied Sciences.

Practical testing of advanced algorithms

Although there is a large amount of research on algorithms and control methods for groups of decentralised, cooperating robots, they are generally validated by simulation only. The Kilobot goes well beyond the state-of-the-art in robotics by allowing the practical testing of advanced algorithms on a large scale through the use of cheap materials and simple programming. “Performing complex behaviours with as little hardware as possible to keep costs down encompasses the spirit of Kilobots,” says Rubenstein.

An important milestone

The technology is being heralded as an important milestone in the development of collective artificial intelligence. “Increasingly we’re going to see large numbers of robots working together to solve problems,” adds Nagpal. The researchers believe that robot swarms might one day tunnel through rubble to find survivors, remove contaminants from the environment, assist dwindling bee populations in pollinating crops and self-assemble to form support structures in collapsed buildings. Success in getting so many robots to self-organise could be a significant milestone in the development of nanotechnology and a collective artificial intelligence, according to the researchers. The next stage is to refine the intelligence and develop smaller robots capable of the same tasks, eventually aiming for the nano scale.

For more information visit http://tinyurl.com/k96uqb4


Share this article:
Share via emailShare via LinkedInPrint this page

Further reading:

igus puts 3D-printed wear materials to the test
igus Motion Control & Drives
A new igus white paper compares its tribological iglidur 3D-printing materials directly with conventional POM, reporting lower wear, more stable friction and up to ten times longer service life in gear testing for customised, low-volume and replacement components.

Read more...
SEW-EURODRIVE’s expanded local engineering capability
SEW-EURODRIVE Editor's Choice Motion Control & Drives
At Electra Mining Africa, SEW-EURODRIVE demonstrated how its expanded local engineering capability, digital technologies and lifecycle support strategy help customers improve reliability, energy efficiency and total cost of ownership across the full life of their drive assets.

Read more...
Latest Danfoss automation drive
Bearing Man Group t/a BMG Motion Control & Drives
BMG has launched the Danfoss iC7-Automation enclosed variable speed drive range in South Africa, backed by significant local stockholding of 400 V models up to 710 kW, approved warranty workshops, and DrivePro digital asset management support.

Read more...
Severe-duty workhorses powering mining
Motion Control & Drives
Mining machines such as rock crushers, pumps and conveyors need motors that combine high torque with robust enclosures, seals and cooling. WEG Africa explains how severe-duty motors deliver more than a decade of reliable performance in harsh conditions while meeting modern energy-efficiency standards.

Read more...
Looking beyond the spec sheet when choosing motion architecture
Motion Control & Drives
When machine builders focus only on torque, speed and price, engineering time, integration effort and long-term maintainability get overlooked. Kollmorgen explains how thinking at the system level, not the component level, leads to better motion architecture choices.

Read more...
Economy drive system closes the drive gap in the entry-level segment
Beckhoff Automation Editor's Choice Motion Control & Drives
Beckhoff has launched an economy drive system pairing its new AX1000 servo drive and AM1000 servomotor with the AF1000 dual-axis variable frequency drive on a shared EtherCAT platform, targeting series machines and price-sensitive markets without sacrificing TwinCAT integration or functional safety.

Read more...
SEW-EURODRIVE showcases modernisation and lifecycle support at Electra Mining Africa 2026
SEW-EURODRIVE Motion Control & Drives
At Electra Mining Africa 2026, SEW-EURODRIVE showed how it has expanded beyond equipment supply into integrated engineering solutions, plant modernisation and long-term lifecycle support for mining and industrial operators across Africa.

Read more...
Mammoet supports critical heavy lift and marine activities for topsides
Motion Control & Drives
Mammoet provided specialised heavy lift and marine logistics support for the Munin topsides on Aker BP’s Yggdrasil North Sea development, including a complex transshipment operation and a tidal-window load-out classified as a Class 1 operation.

Read more...
High voltage need not mean high complexity
Motion Control & Drives
Kollmorgen has extended its Essentials motion platform into 400 to 480 V high-voltage applications, allowing machine builders to right-size their motion systems without stepping up to unnecessarily complex or over-specified solutions.

Read more...
Sinamics G200 frequency converter for general applications
Siemens South Africa Motion Control & Drives
Siemens has expanded its Sinamics portfolio with the G200, a compact general-purpose frequency converter that supports Profinet, TIA Portal integration and built-in safety and cybersecurity functions for a wide range of industrial drive applications.

Read more...


While every effort has been made to ensure the accuracy of the information contained herein, the publisher and its agents cannot be held responsible for any errors contained, or any loss incurred as a result. Articles published do not necessarily reflect the views of the publishers. The editor reserves the right to alter or cut copy. Articles submitted are deemed to have been cleared for publication. Advertisements and company contact details are published as provided by the advertiser. Technews Publishing (Pty) Ltd cannot be held responsible for the accuracy or veracity of supplied material.


© Technews Publishing (Pty) Ltd | All Rights Reserved

