
High-bay warehouses with conventional automated storage and retrieval machines are in widespread use. However, the payload in relation to the total mass that has to be moved is very small.
Within the scope of a project sponsored by the German Federal Ministry of Education and Research, EffizienzCluster LogistikRuhr, researchers at the University of Duisburg-Essen have now eliminated this disparity with the help of parallel cable robots. In doing so they have benefitted from the inexpensive and flexible control technology enabled by PC-based control. Furthermore, the scientific know-how existing in Matlab/Simulink models can be integrated into the controller in the simplest way using TwinCAT 3 software.
Automated storage and retrieval (SRM) machines are used today in intralogistics. By means of a rail-mounted drive unit and a lifting unit, a storage/retrieval device is positioned in front of the high rack, which puts goods into storage or removes them again in a targeted manner. In the process, current SRMs move the large mass of 1 to 2 tons of drive unit, mast and lifting unit in order to transport small parts with a payload of only 20 to 50 kg.
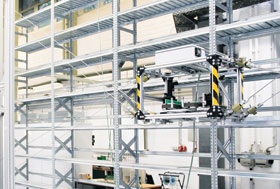
In order to avoid this, a light-weight platform with an integrated storage/retrieval device now replaces the complete drive and lifting unit. This platform is moved in front of the high rack as a so-called cable robot with eight tensioned cables. The result is a mechanically simple and extremely lightweight system, which can also be constructed in the most diverse sizes without the mass-related height limits that need to be observed with traditional high-bay warehouses.
Energy-saving and performance potential
The enormous reduction in mass of the cable robot technology, which amounts to over 90% compared with conventional technology, leads to enormous increases in performance and a very good energy balance at the same time. The concept has already been implemented in 2012 at the University of Duisburg-Essen with a 6 metre high, 12 metre wide and 1 metre deep prototype. It was realised by the departments of Mechatronics and Transport Systems/Logistics as well as the department of Computer Application in Design. Dr Tobias Bruckmann from the Faculty of Mechatronics summarises the result: “We have achieved an extremely improved mass ratio, because the end effector which has to be moved – the light-weight platform with the storage/retrieval device – weighs only 80 kg and can take a payload of up to 20 kg. A model calculation based on a simple model and idealised assumptions resulted in a reduction in energy consumption of about 70% compared to a conventional storage and retrieval machine.”
Regarding the attainable storage/retrieval performance, there is similarly a high optimisation potential. Typical SRM values – a platform speed of 6 m/s and a platform acceleration of 5 m/s² – were taken as design specifications at the start of the project. Christian Sturm, also from the Faculty of Mechatronics, adds: “Winch drives with a rating of 7 kW are required in order to attain these values. In our prototype we even use 14 kW drives, enabling considerably higher speeds and acceleration, especially since the more powerful and thus heavier drives don’t have to be moved as they do in the classic storage and retrieval machine, so their higher mass has no impact.”
High-performance, industrially compatible control technology
In order to ensure a safe system operation at all times, the highest demands are placed on the control system. In addition to that, eight servo drives have to be driven synchronously, and force sensors and angle encoders for all eight cables have to be read simultaneously. These measured values supply the data for a model-based controller that demands a high-performance real-time platform. Dr Bruckmann adds: “Since this controller was implemented in Matlab/Simulink, the TwinCAT 3 automation suite from Beckhoff represented an ideal, powerful and affordable solution. Instead of prototype control systems for academic use, it was thus possible to make use of proven standard components.”
The C6640 Control Cabinet PC provides more than enough computing performance for the entire control technology. It communicates by EtherCAT with sensors and drives as well as with components of the light-weight platform, such as the storage/retrieval device and the laser scanner for fine positioning. Since the cable robot operation requires extremely reliable measurements of the cable forces, the researchers use the EL3356-0010 Analog Input Terminal with eXtreme Fast Control (XFC). As Sturm explains: “In order to be able to move the light-weight platform precisely and with as little vibration as possible, the cable tensions are measured by load cells and EL3356-0010 EtherCAT Terminals. These values are then processed by the control algorithms implemented in Matlab/Simulink. We also benefitted substantially from the XFC oversampling function with an oversampling factor of 10. The EL3356 0010 offers an outstanding sampling rate, which already provides considerably smoothed signals in relation to our current control cycle time of 1 ms. In this way the signals can be processed in the controllers without any further preprocessing. Furthermore, parameterisation and connection are very simple and also the terminals are very cost-efficient.”
A critical advantage of the control system is its industrial compatibility. It therefore represents the ideal basis for further work on the main thrust of the research – the control algorithms. Dr Bruckmann confirms this: “Instead of decentralised controllers for drives and platform, we need only one central real-time PC with a wide data bus and it doesn’t matter whether we have to transmit measured values over just one metre or over twenty metres to the platform. In earlier prototypes data acquisition and, in particular, motor control over large distances were rather complex. We were surprised at how simple the commissioning of our new, large prototype was. There is another benefit. The Beckhoff technology also offers a great advantage with regard to practical use, in other words series production, because on the one hand we can use the familiar Matlab/Simulink world and on the other the user can make unlimited use of common IEC 61131-3 languages. Thanks to this universality it is not necessary to integrate a second control system, for example for the addition of safety functionality – PC control is ready to provide everything required for industrial use on a single platform.”
A milestone for developing future-proof systems
The researchers view the simple interfacing of Matlab/Simulink with TwinCAT 3 as a true milestone, because only that enables them to access an industrially compatible system in a simple manner from their scientific field of work. In addition, the entire hardware level can be structured very simply and modularly using TwinCAT 3 and EtherCAT. Christian Sturm explains: “All components connected to the EtherCAT system are represented as a hardware image under TwinCAT 3, so that all devices can be linked to the controller with ease via communication with our software module. In addition the system can be extended, for example with further I/O modules, simply and above all inexpensively thanks to the scalabe EtherCAT system – at a fraction of the costs compared to conventional systems.”
TwinCAT 3 similarly offers potential for future developments. Its support for multi-core technology, for instance, is of particular importance, especially with regard to industrial use, since the tasks necessary for this such as warehouse management and safety concepts can be outsourced to their own processor cores if necessary. In addition there is the openness through integration into Visual Studio, which according to Dr Bruckmann is a very attractive feature. The academic users would be only too willing to use this new programming technology to create a complete project, from real-time programming to the visualisation in Visual Studio. The next step for the cable robot project is to integrate software blocks written in C/C++ as well and in this way to be able to access other hardware interfaces, for example a camera system.
For more information contact Kenneth McPherson, Beckhoff Automation, +27 (0)11 795 2898, k.mcpherson@beckhoff.com, www.beckhoff.co.za
| Tel: | +27 11 795 2898 |
| Email: | info@beckhoff.co.za |
| www: | www.beckhoff.com |
| Articles: | More information and articles about Beckhoff Automation |




© Technews Publishing (Pty) Ltd | All Rights Reserved
 printer friendly version